Their story, in their words…
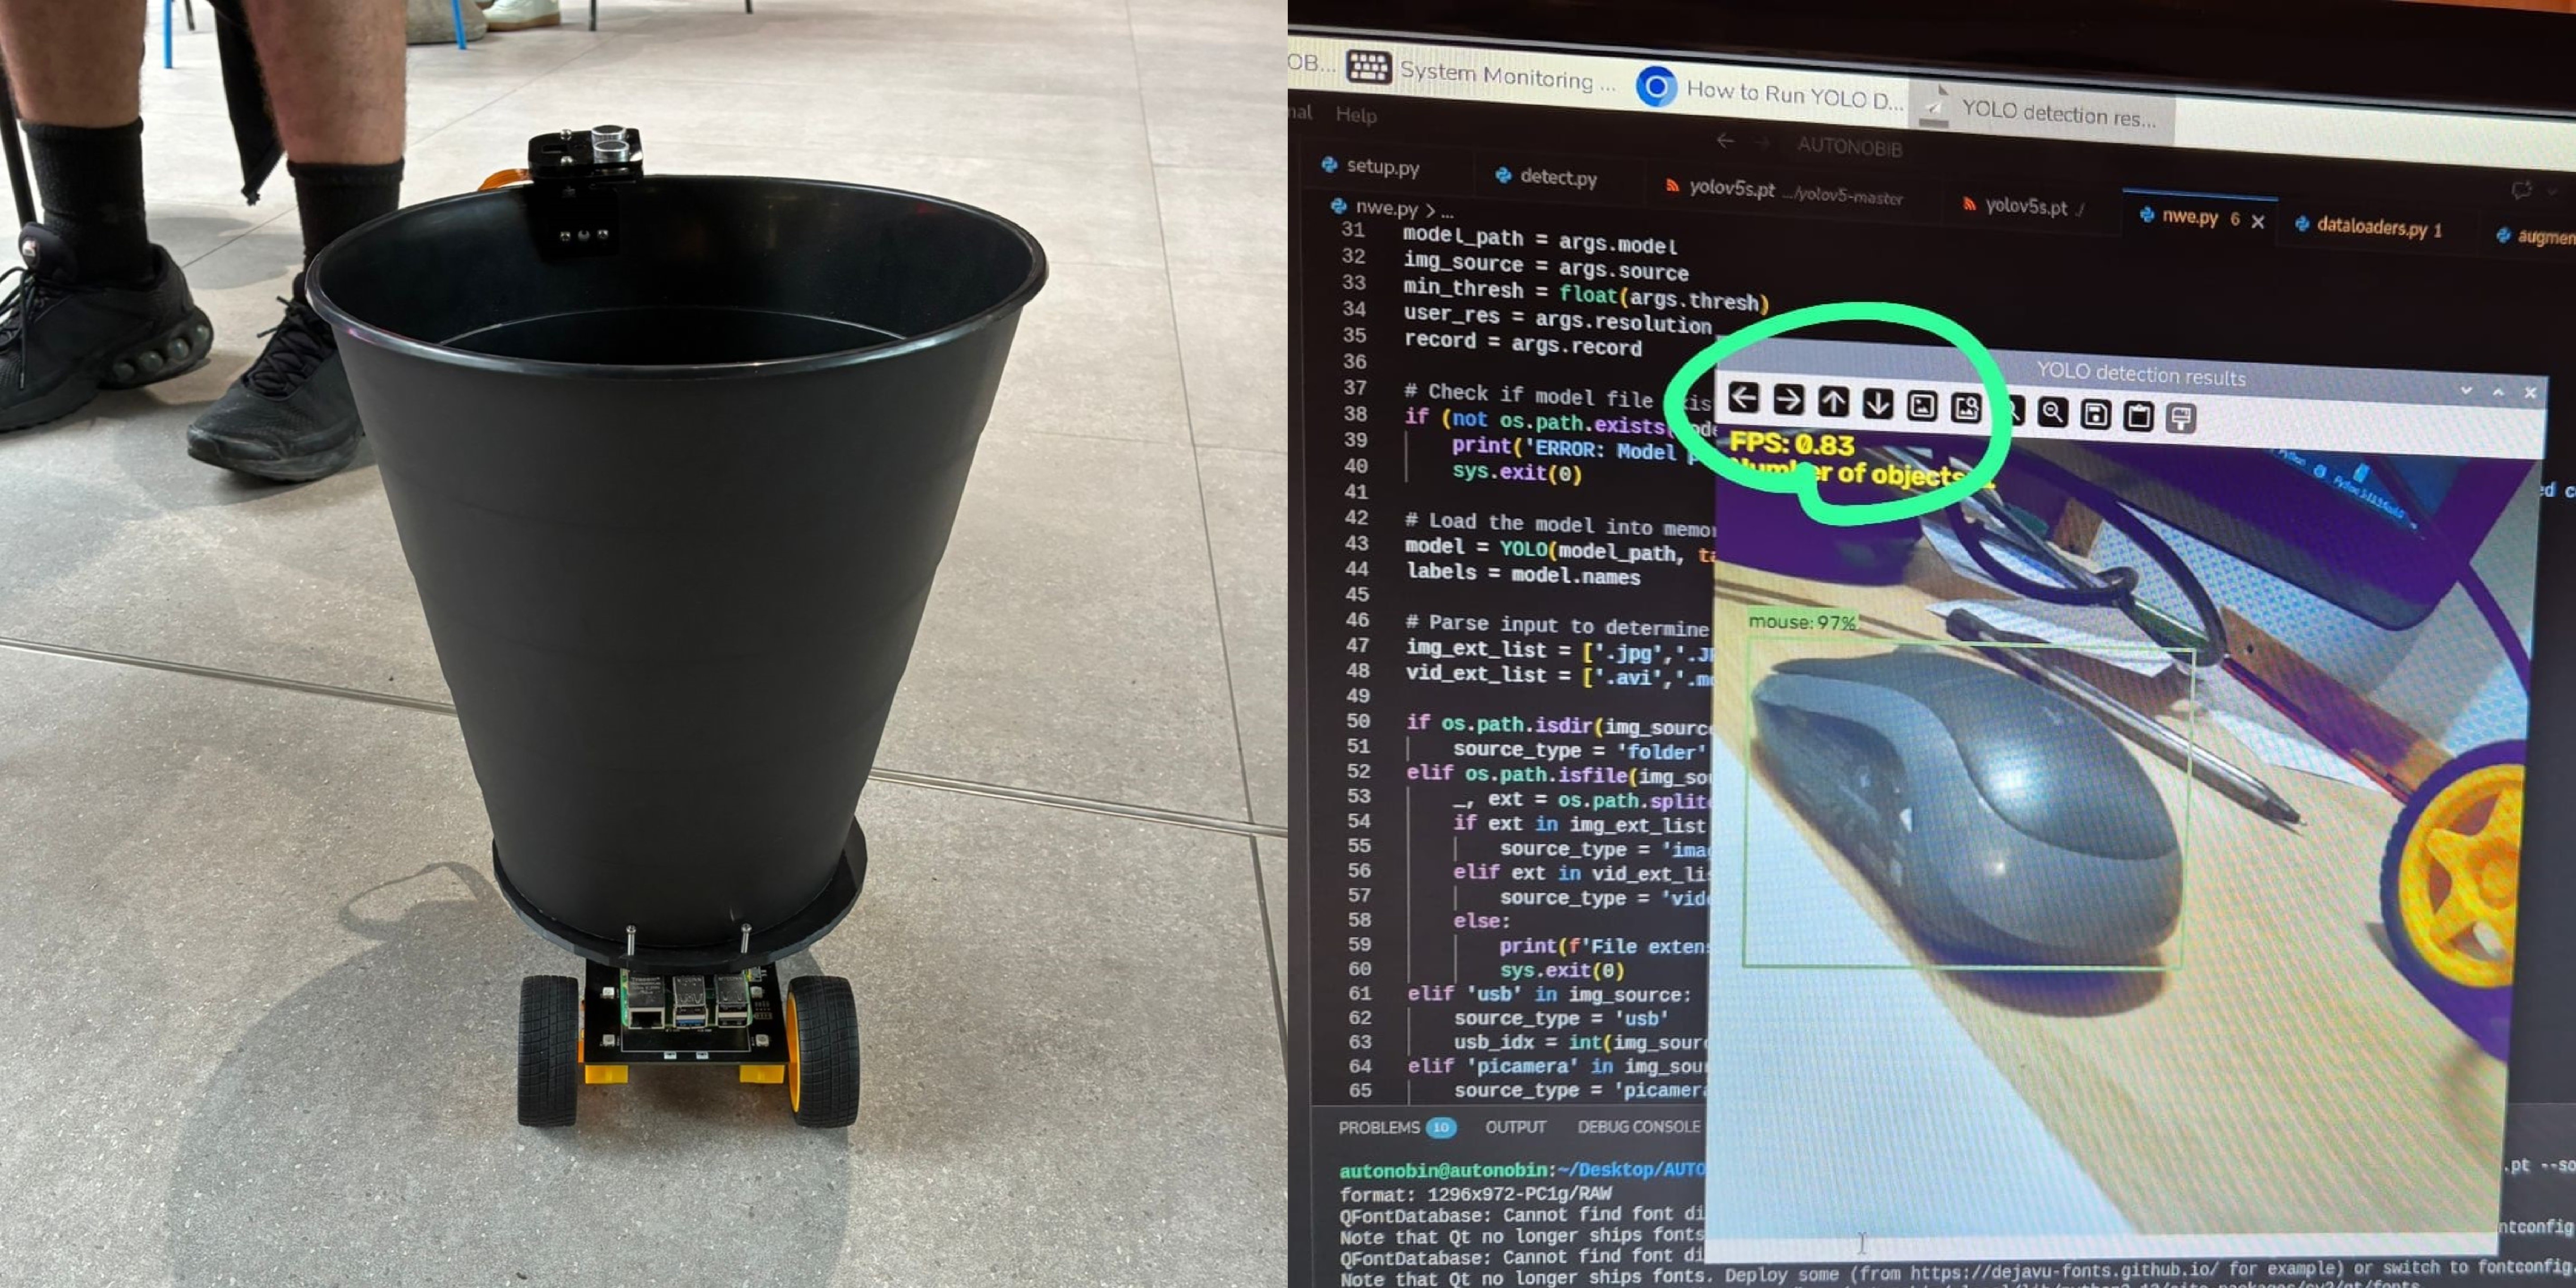
We created a bin that aims for the rubbish that you throw at it, rather than requiring you to accurately aim for the bin yourself. Using a moving robot subassembly, we developed an algorithm which utilised a camera to detect moving objects and track their direction of movement. This tracking enabled the robot to predict where the thrown item was travelling and move the bin in the direction of the object, effectively allowing it to aim for the rubbish as it fell and catch the item.
From this experience, we learned more about how machines are able to recognise and identify certain objects through repeatedly being given training data consisting of images of those objects. We also gained experience in designing and building a chassis for our robot, while considering how the different components would fit together and allow the robot to move effectively. Throughout the project, we had to test and improve both the physical design and the software controlling the robot to make sure that everything worked together.
Overall, the project gave us the opportunity to put our computer science skills to the test in a practical and enjoyable way. It allowed us to explore areas such as object recognition, image tracking, programming and robotics, whilst also developing our teamwork and problem-solving skills. Most importantly, we were able to learn about these technologies through a hands-on experience while enjoying the project and working together with friends.