Their story, in their words…
When I started this project, my goal was to build a movable camera robot that could drive around on wheels while also detecting obstacles in its surroundings. I wanted to improve my robotics knowledge and strengthen my coding skills by creating something practical and interactive.
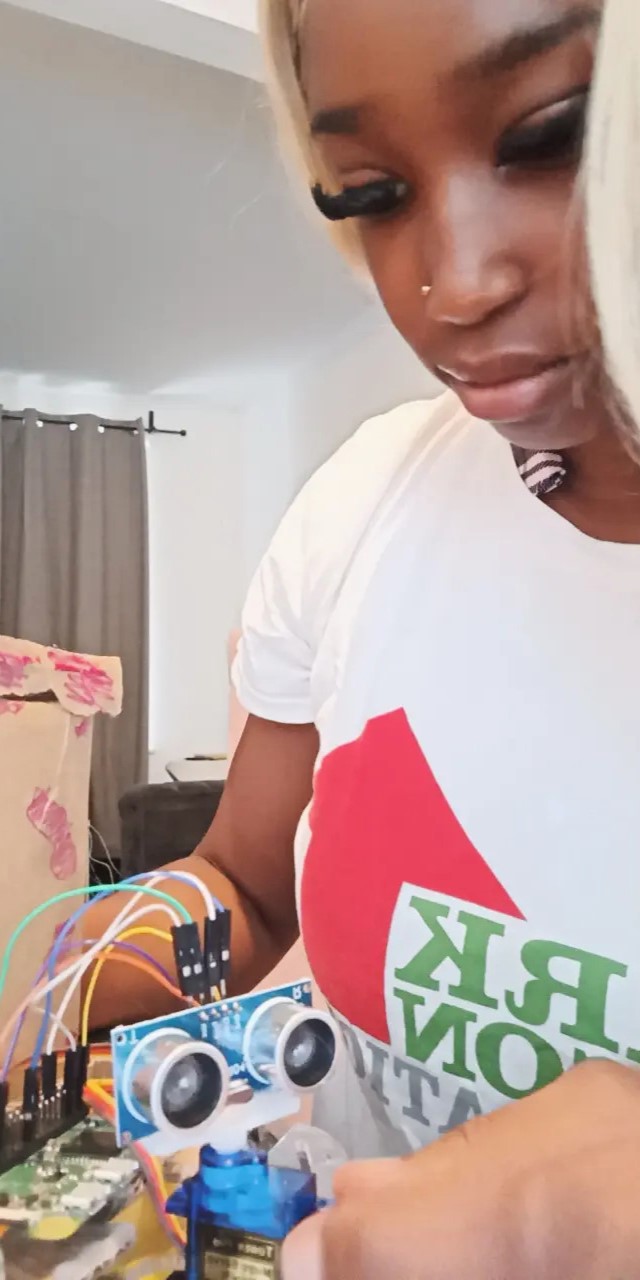
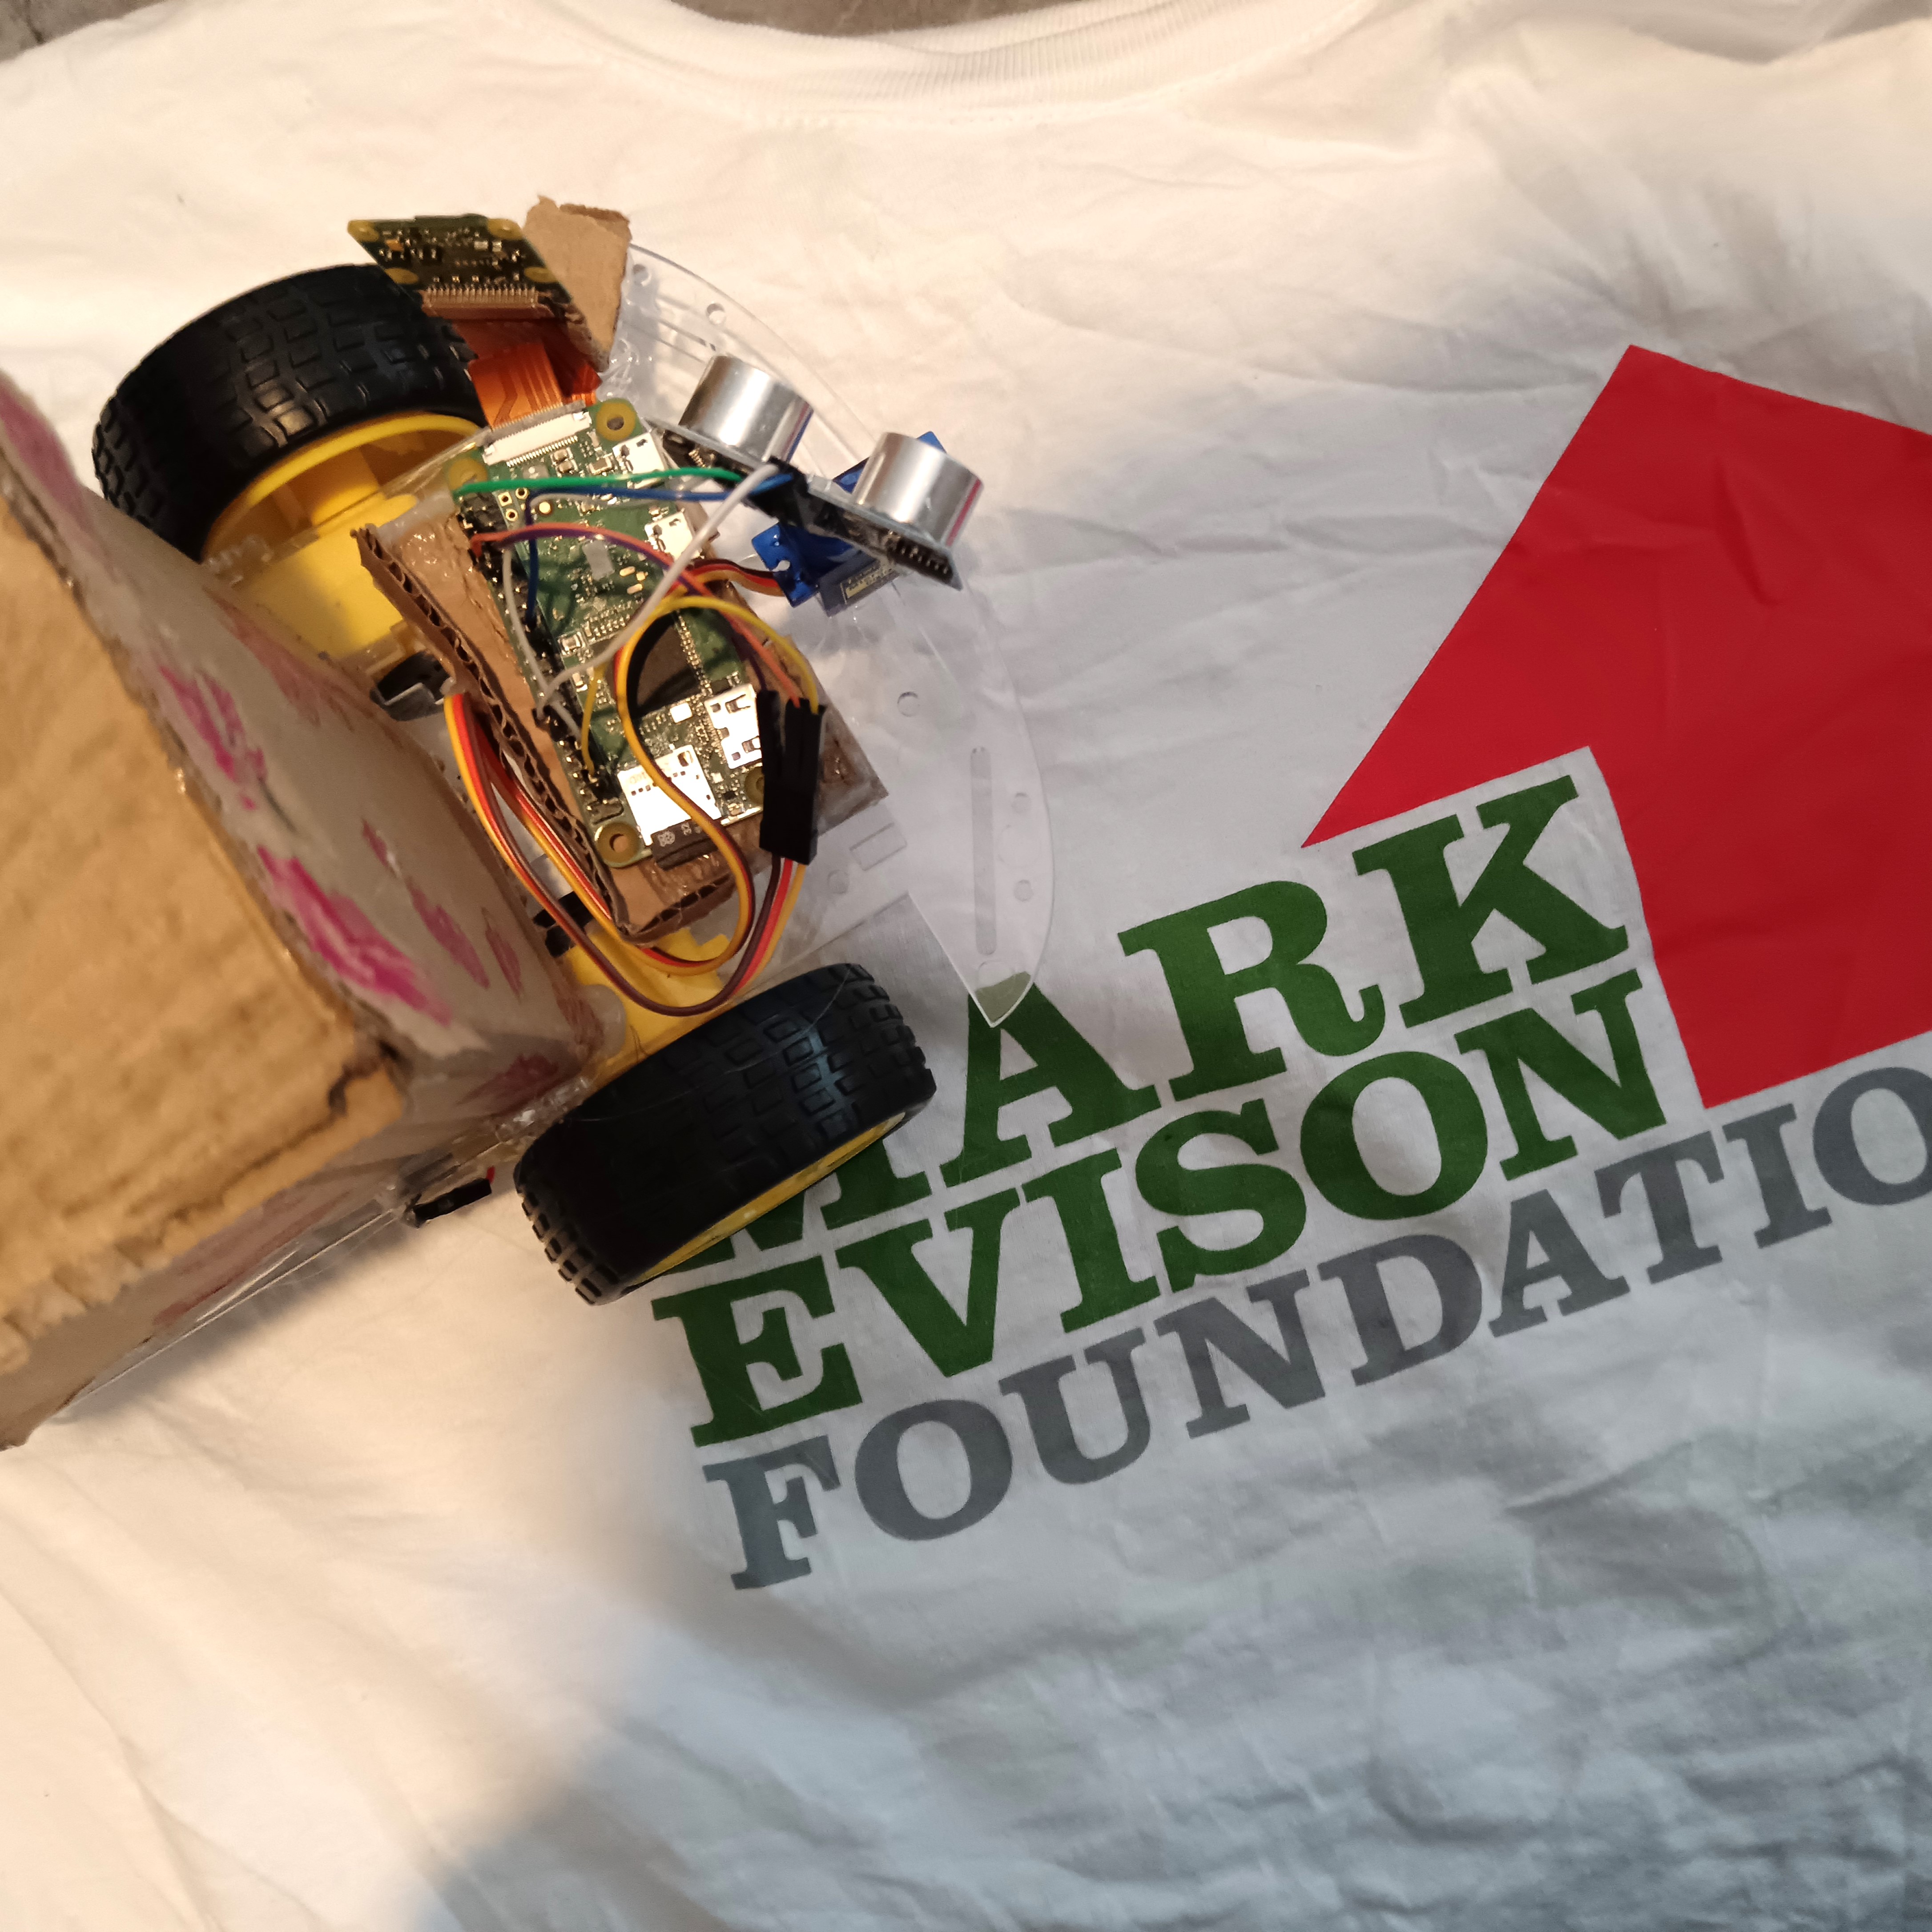
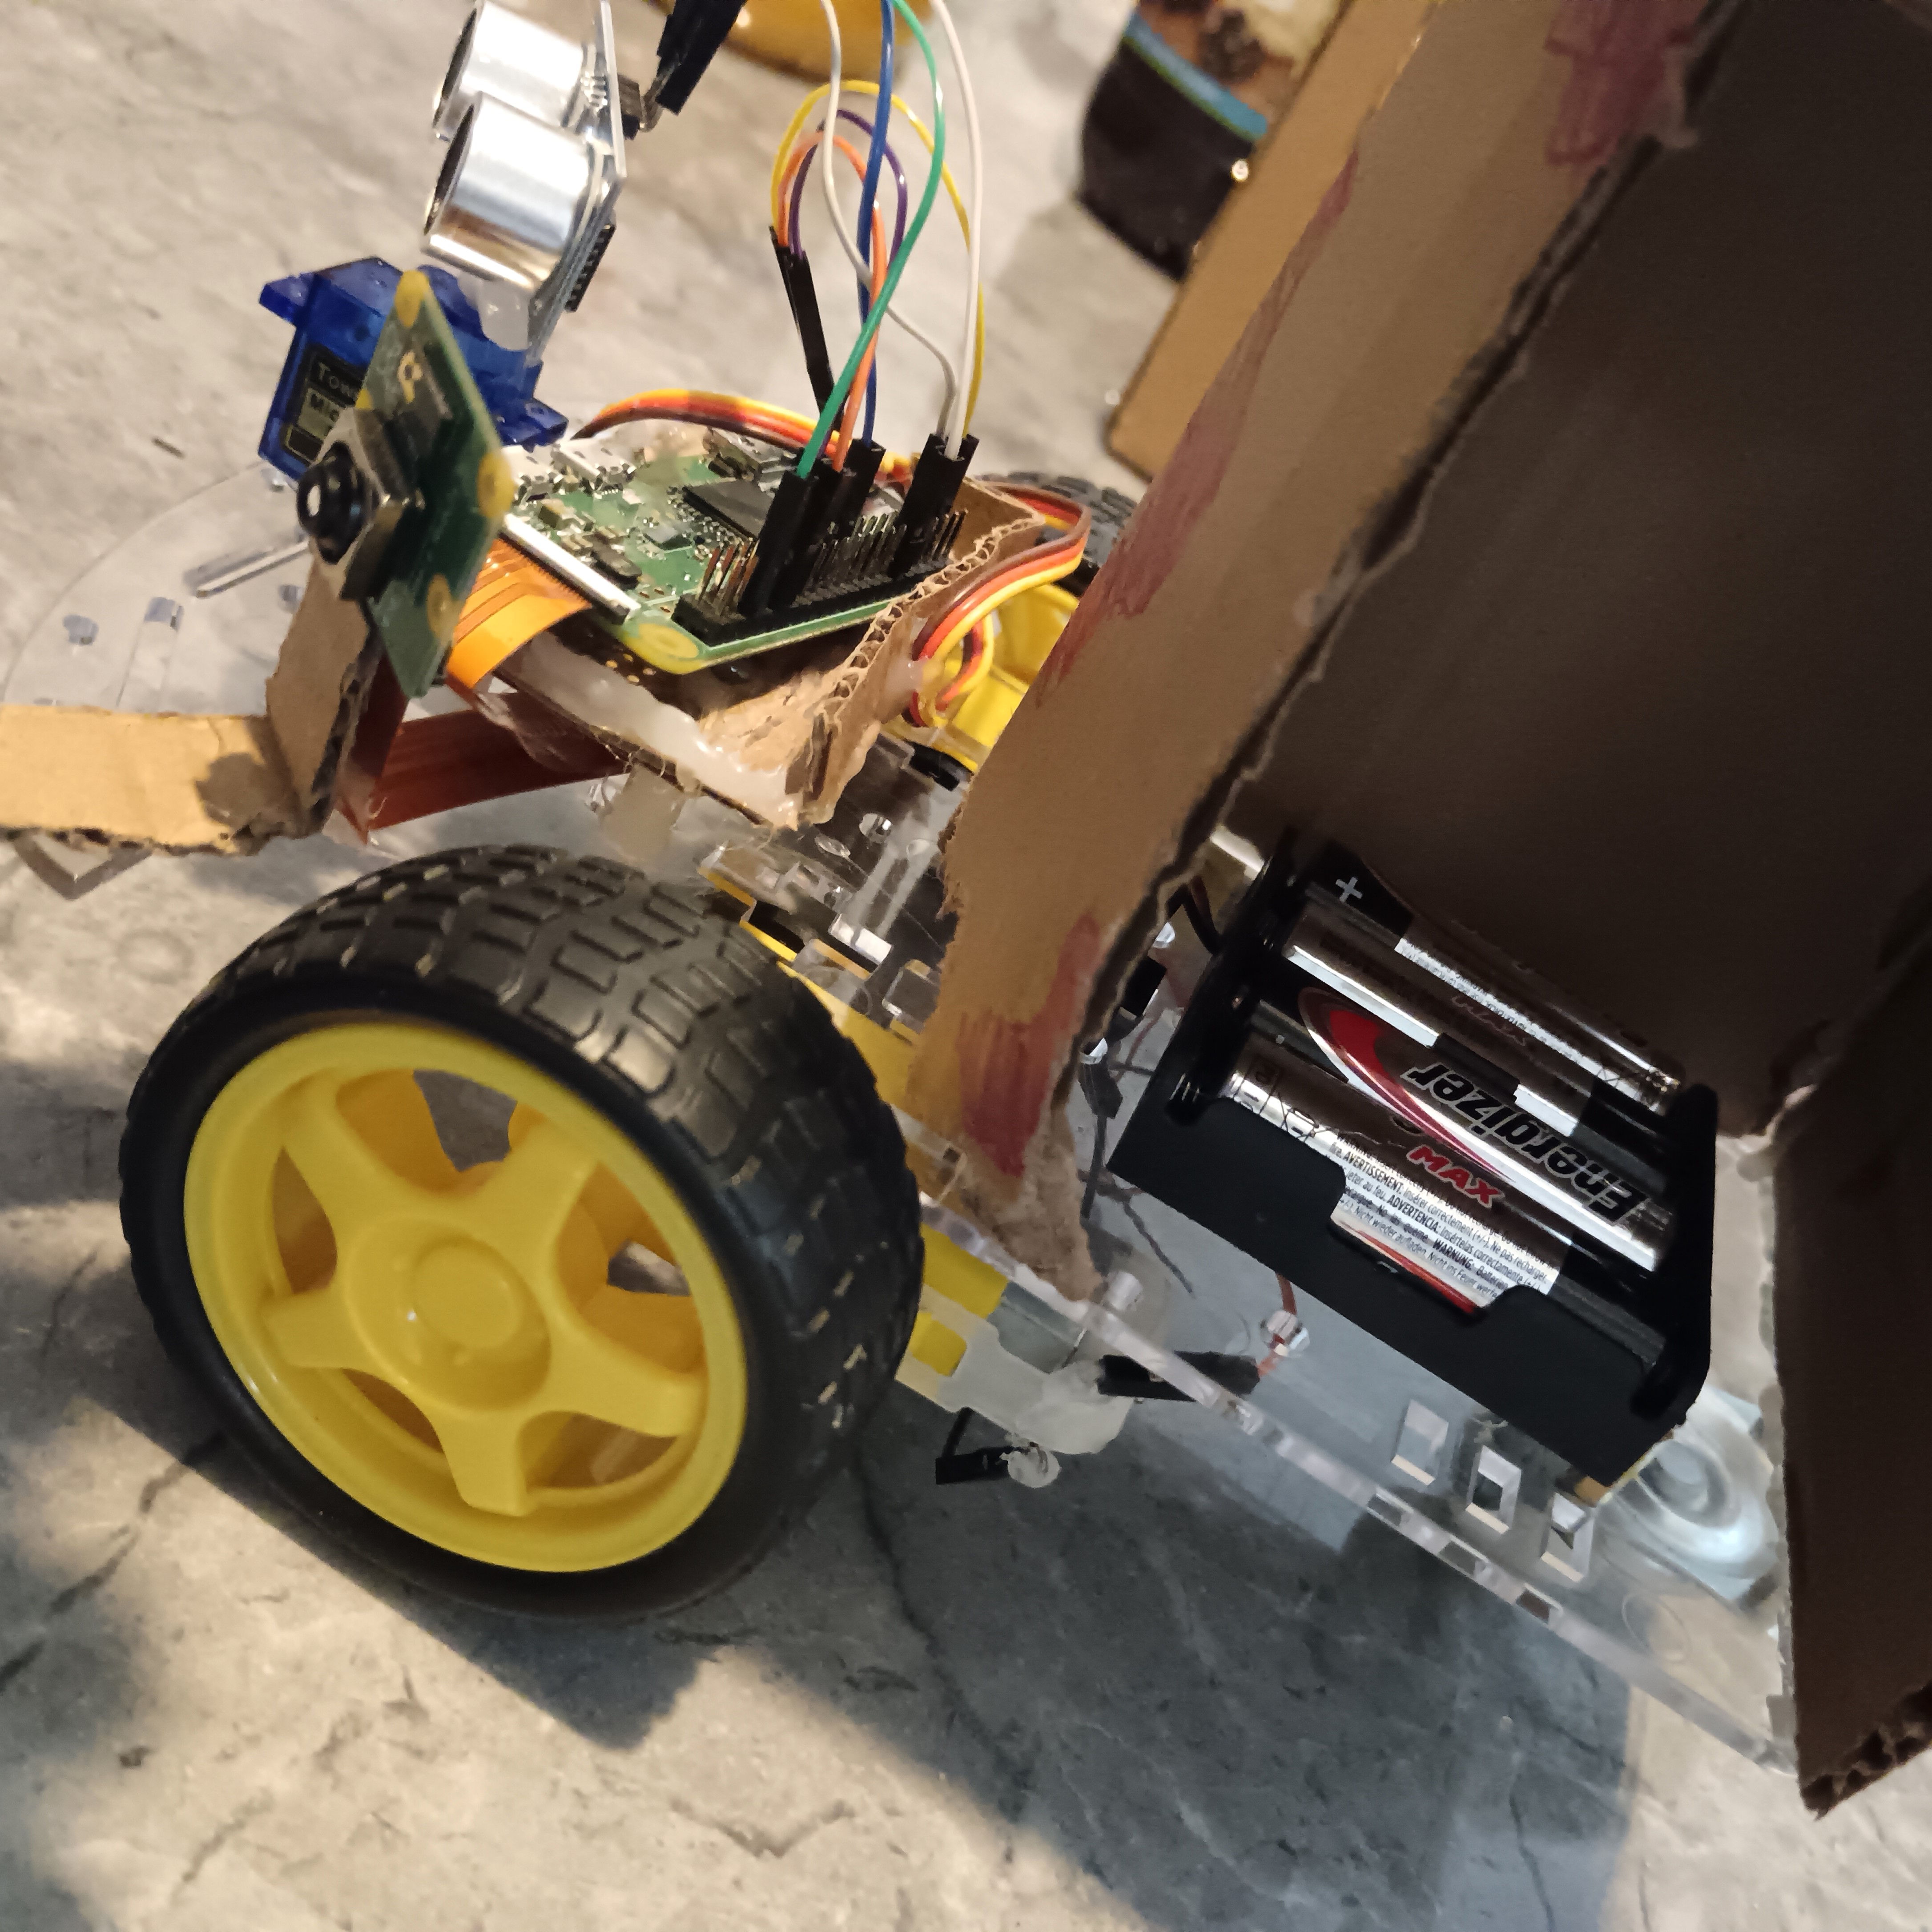
The project involved building a camera module mounted on my constructed wheeled robot base powered by a Raspberry Pi Zero 2 W. The robot is able to move around, capture photos and videos and use ultrasonic sensors to detect nearby obstacles.
I began by preparing the base of the robot, including the motors, wheels, battery pack and surface. This helped me plan where each component needed to be placed before assembling everything together. Next, I set up the Raspberry Pi Zero 2 W and attached the camera module. After that, I connected the Raspberry Pi to the ultrasonic sensors using male to female jumper wires through a soldered board, then completed the SD card setup and uploaded the code needed to control the robot.
Once the electronics were working, I focused on the exterior design. I used cardboard and felt pens to create a truck inspired camouflage style that gave the robot a spy themed appearance. I carefully measured and cut each side of the cardboard so it fitted the robot properly, while leaving one side open to allow easy access for adjustments or emergencies. I also designed the roof with a slight slope of around 8 to 10 degrees so that any debris could run off instead of collecting on top.
Overall, I think the project was successful, especially as it was my first robotics project. I enjoyed doing something completely different from what I am usually used to and it gave me the opportunity to spend time developing skills that I often overlook. It improved my creativity, coding ability, understanding of circuits and problem solving skills.
The robot worked about 80% as I had planned. I faced several challenges, including wiring complications and difficulties getting the robot to run correctly. At one point, I also struggled to transfer data between different parts of the project so it was ready to use. Although these problems were frustrating, I learned how to work through them and in the end the project came together successfully.
This project gave me my first experience of building a robot from scratch. It taught me how to work from a basic foundation, combine hardware with software, and understand how different materials and electronic components work together. Overall, it was a valuable learning experience that has made me more interested in robotics and coding.