
Their story, in their words…
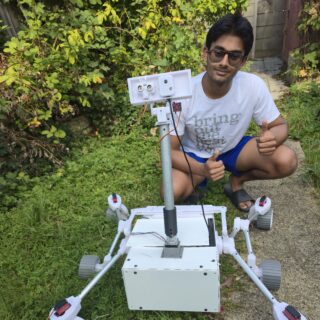
This project consisted of making a scale prototype of the Perseverance rover currently on Mars right now. I decided to make it to develop my independent problem-solving skills and to satisfy my younger self who was so interested in Space.
It was designed on Fusion 360 using the actual rover 3D model as a canvas to design parts to replicate the base features. Predominantly this involved the Rocker-bogie wheel mechanism which works to stabilize the rover in rough terrain. This section involved designing components that I 3D printed and connected to aluminum tubing and ball bearings to replicate this function. For the main frame I usesd aluminum T slot channel as the main frame and covered it in thin laser cut Acrylic to replicate the rover’s white body.
The electronic systems involve a Wifi enabled Arduino mega that controls the 6 motors and 8 servos as well as the one stepper motor for rotating the camera module. The rover uses Ackermann steering just like the real rover with 4 servos turning to allow rotation. The camera module consists of an ESP 32 Cam using its AI object detection to stream video and an Ultrasonic sensor for the purpose of distance calculations when I automate the rover.
The project was a great success with the systems working and moving about but in the future after my exams I plan to develop it further for automation and perhaps with a robot arm just like in the real Mars rover.
Through it I learn so many things about electronics and designing, through the iterative design process learning to keep improving the design till it worked. I would definitely recommend people to push themselves in the future to complete projects like mine to develop skills and thank you to the Mark Evison foundation for enabling this to be accomplished by me.


